 ROS Index
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps



opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
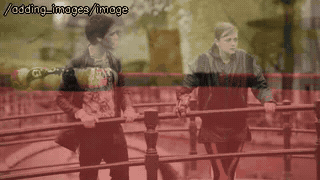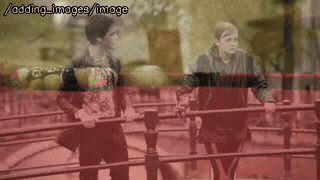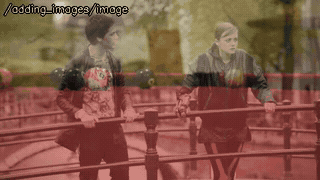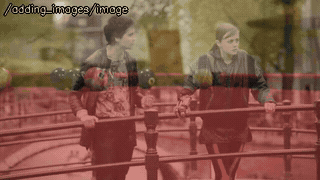 adding_images |
 discrete_fourier_transform |
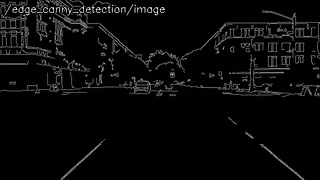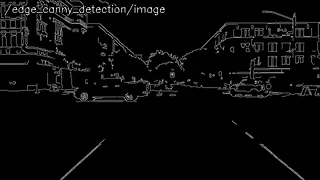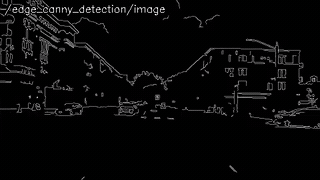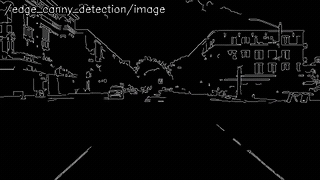 edge_detection |
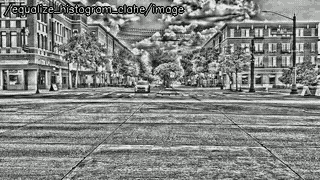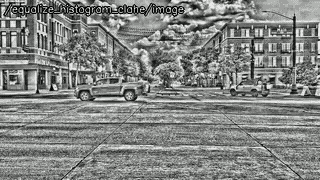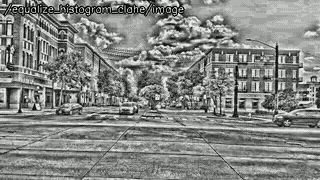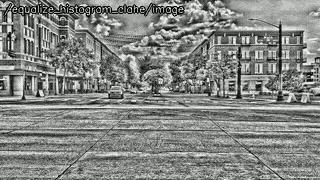 equalize_histogram |
 morphology |
 pyramids |
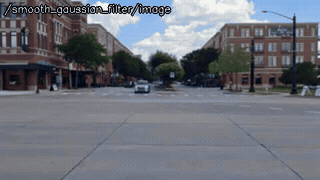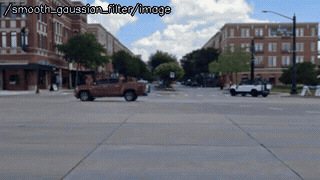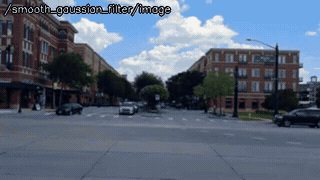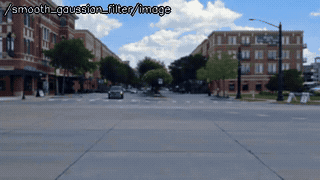 smoothing |
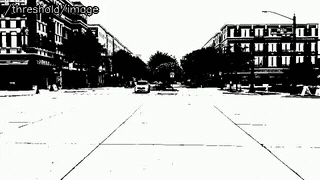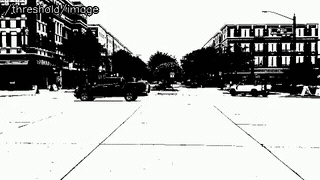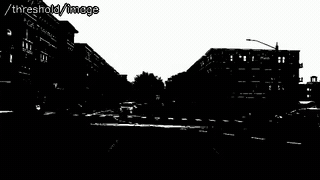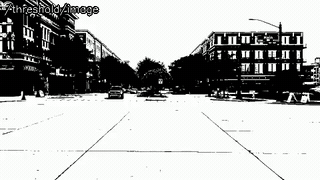 threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
 hsv_color_filter |
 hls_color_filter |
 lab_color_filter |
 rgb_color_filter |
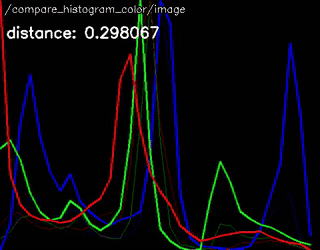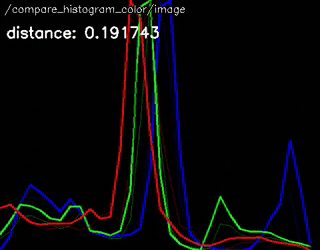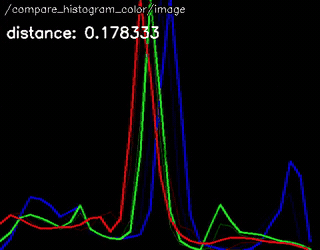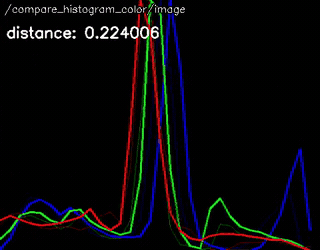 compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
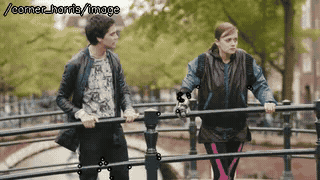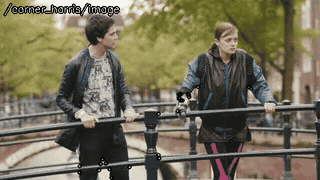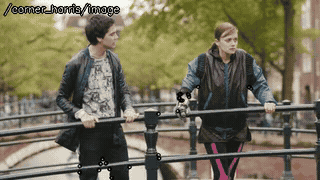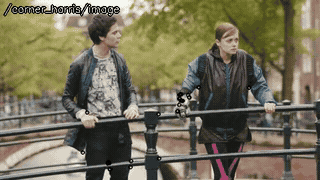 corner_harris |
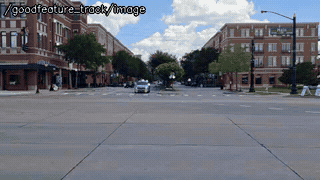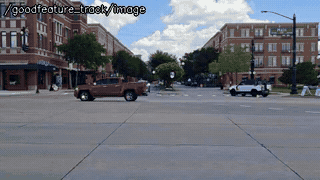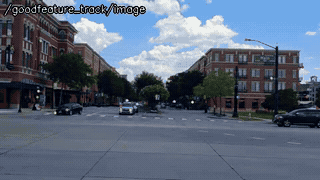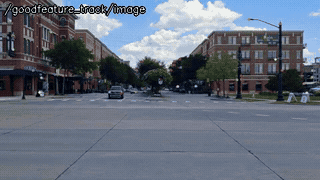 goodfeature_track |
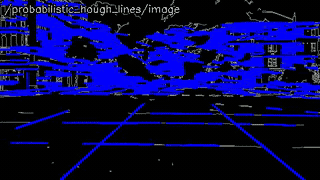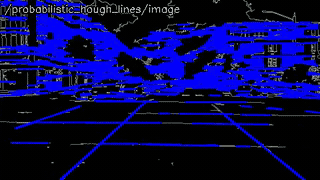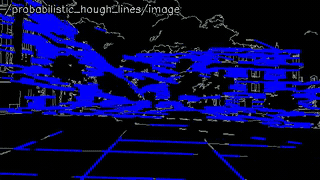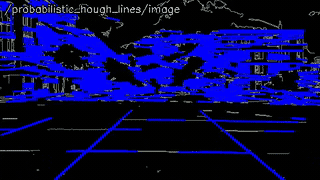 hough_lines |
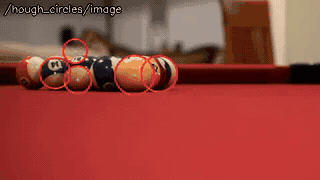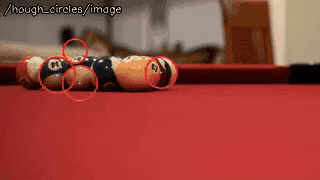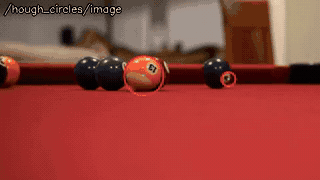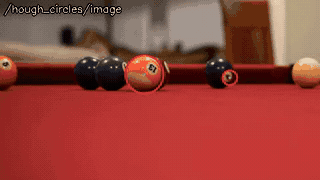 hough_circles |
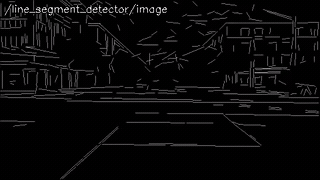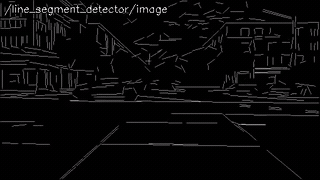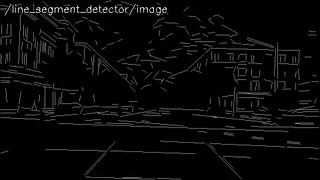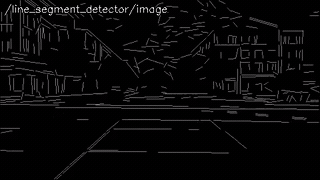 line_segment_detector |
 find_contours |
 general_contours |
 contour_moments |
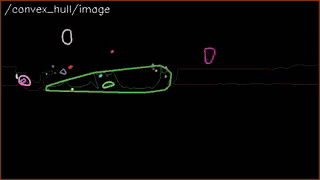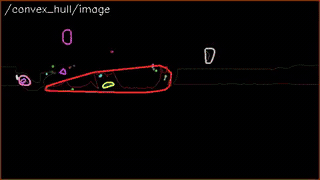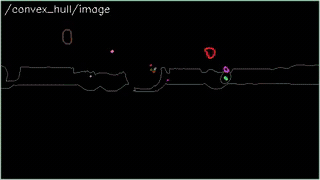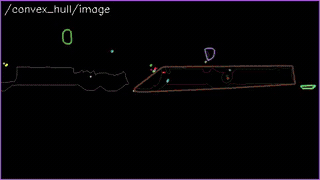 convex_hull |
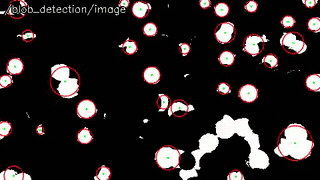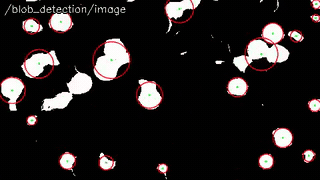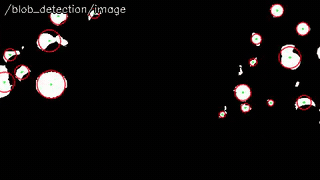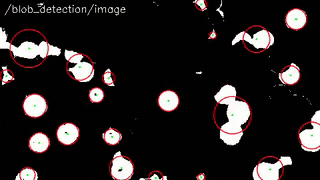 blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
 segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_perception | |
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_perception | |
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | 3.0.0 |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/3.0.0/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_perception | |
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_perception | |
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]
Services
Plugins
Recent questions tagged opencv_apps at Robotics Stack Exchange
|
|
opencv_apps package from opencv_apps repoopencv_apps |
ROS Distro
|
Package Summary
| Version | 3.0.0 |
| License | BSD |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Checkout URI | https://github.com/ros-perception/opencv_apps.git |
| VCS Type | git |
| VCS Version | indigo |
| Last Updated | 2026-11-14 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Additional Links
Maintainers
- Kei Okada
Authors
- Kei Okada
opencv_apps
opencv_apps provides the ROS nodes that run the functions of OpenCV: image processing,
features, contours, optical flows, tracking, detection and recognition, and the deep learning models of cv::dnn.
Each node subscribes an image topic, and publishes its results as messages and as an image, so you can use the
functions of OpenCV just by running a launch file. The same source supports both ROS 1 and ROS 2.
sudo apt install ros-$ROS_DISTRO-opencv-apps ros-$ROS_DISTRO-image-publisher
# ROS 2, terminal 1: publish the USB camera as image (0: the number of the camera, /dev/video0)
ros2 run image_publisher image_publisher_node 0 --ros-args -r image_raw:=image
# ROS 2, terminal 2: the face detection on it
ros2 launch opencv_apps face_detection.launch.xml image:=image
# ROS 1 (ROS One), terminal 1: publish the USB camera as camera/image_raw (0: /dev/video0)
rosrun image_publisher image_publisher 0 __name:=camera
# ROS 1 (ROS One), terminal 2: the face detection on it
roslaunch opencv_apps face_detection.launch image:=camera/image_raw use_opencv4:=true
Documentation: https://ros-perception.github.io/opencv_apps/ (the topics, the parameters and the usage of the nodes)
What opencv_apps can do
Image processing
Filter and transform the images: edges, histogram equalization, morphology, image pyramids, smoothing, thresholds and the Fourier transform.
adding_images |
discrete_fourier_transform |
edge_detection |
equalize_histogram |
morphology |
pyramids |
smoothing |
threshold |
Color
Extract the pixels in a range of colors in HSV, HLS, Lab* or RGB, and compare the color histograms.
hsv_color_filter |
hls_color_filter |
lab_color_filter |
rgb_color_filter |
compare_histogram |
Features, lines and contours
Find the corners, lines, line segments, circles, blobs and contours, with their moments and convex hulls.
corner_harris |
goodfeature_track |
hough_lines |
hough_circles |
line_segment_detector |
find_contours |
general_contours |
contour_moments |
convex_hull |
blob_detection |
Segmentation
Separate the foreground and the objects: background subtraction, connected components and watershed.
segment_objects |
File truncated at 100 lines [see the full file](https://github.com/ros-perception/opencv_apps/tree/indigo/./README.md)
Changelog for package opencv_apps
3.0.0 (2026-11-14)
- Port to ROS2 (jazzy, kilted, lyrical), keeping ROS1 (noetic, ROS One) with the same source and compat headers (#153)
- Follow-ups to the ROS2 port: lk_flow re-detection, ROS1 parameter clamping, zero-copy publishing (#154)
- Add OpenCV 4 nodes: dnn_face_detection (YuNet), dnn_face_recognition (SFace), dnn_object_detection (YOLOX), qrcode_detection, barcode_detection and aruco_detection (#165)
- Fixes of the dnn and aruco_detection nodes: model cache per URL scheme, fisheye camera model (#169)
- Add DNN nodes: dnn_text_detection (OCR), dnn_semantic_segmentation, dnn_depth_estimation, dnn_pose_estimation, dnn_hand_pose_estimation (with tracking and smoothing, Keypoint / Skeleton messages), dnn_image_classification and dnn_facial_expression_recognition (#171)
- Add tracking node with the OpenCV trackers (port of #129), and dnn_tracking node with the DNN based trackers (DaSiamRPN, NanoTrack, VitTrack), with the same interface (~set_roi, ~output) (#157, #170, #172)
- Add match_template node (port of #68) (#163)
- Add background_subtraction node (port of #62) (#164)
- Add blob_detection node (port of #130) (#162)
- Add compare_histogram node (port of #128, #104) (#160)
- Add line_segment_detector node (port of #35) (#159)
- color filters: publish the pixels in the color space as PointCloud2 (port of #61) (#161)
- camshift: tracking rectangle from parameters, publish the confidence (port of #141) (#158)
- morph_size range, Release build, bgr8 encoding (ports of #135, #105 and #102) (#155)
- Fix the descriptions of theta of hough_lines, morph_size of morphology, filter_by_inertia of blob_detection and padding of people_detect, and the range of morph_operator of morphology (0 - 4) (#173)
- Add the documentation, published to https://ros-perception.github.io/opencv_apps/, with the demos of all the nodes, and a new README (#173)
- Add CONTRIBUTING.md (rewrite of #110) (#156)
- CI: ROS-O test, fix flaky ROS2 tests (Fast DDS shared memory for the images) (#152, #167)
- Contributors: Kei Okada, Fan Shi, HuiShiSerenaShi, Iori Yanokura, Ryosuke Tajima
2.0.3 (2025-05-22)
- [lk_flow] Keep matching information for sparse optical flow (#149)
- use bgr8 for output visualization (#145)
- add ROS-O test (#147)
- Suppress cmake warning (#146)
- [TEST] Fix catkin_lint version 1.6.18 to avoid [cmake_minimum_required]{.title-ref} error (#143)
- Add sync_.reset/async_.reset to destructor in face_recognition (#139)
- fix github actions (#140)
- fix missing .git directory (#136)
- Add histogram equalization default and clahe (#126)
- check all output of test/test-pyramids.test (#127)
- tests: properly remap camera_info
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| jsk_perception | |
| roseus_tutorials |
Launch files
- launch/adding_images.launch
-
- node_name [default: adding_images]
- image1 [default: image1] — The image topic. Should be remapped to the name of the real image topic.
- image2 [default: image2] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- alpha [default: 0.5] — Weight of the first array elements
- gamma [default: 0] — Scalar added to each sum
- approximate_sync [default: false] — Flag of approximate_sync. If this value is false, image1 and image2 synchronize exact time.
- launch/aruco_detection.launch
-
- node_name [default: aruco_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- dictionary [default: DICT_4X4_50] — Predefined dictionary of the markers, e.g. DICT_4X4_50, DICT_6X6_250, DICT_ARUCO_ORIGINAL, DICT_APRILTAG_36h11
- marker_length [default: 0.0] — Length of the side of the markers in meters, to publish their poses with the camera info (use_camera_info:=true), 0 not to publish
- rectified [default: false] — The image is rectified (e.g. image_rect of image_proc), then the poses are estimated with the intrinsics of P of the camera info without distortion, instead of K and D
- launch/background_subtraction.launch
-
- node_name [default: background_subtraction]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the foreground mask
- queue_size [default: 3] — Specify queue_size of input image subscribers
- method [default: 0] — Background subtraction method, 0: MOG2, 1: KNN, 2: MOG, 3: GMG, 4: CNT, 5: GSOC, 6: LSBP (MOG, GMG, CNT, GSOC and LSBP need the bgsegm module of opencv_contrib, otherwise MOG2 is used)
- learning_rate [default: -1.0] — Learning rate of the background model, negative: automatically chosen, 0: not updated, 1: reinitialized from the last frame (CNT, GSOC and LSBP may still update the model at 0, and GMG, GSOC and LSBP do not reinitialize it at 1)
- launch/barcode_detection.launch
-
- node_name [default: barcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/blob_detection.launch
-
- node_name [default: blob_detection]
- image [default: image] — The image topic, typically a binary mask (e.g. hsv_color_filter/image). Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the detected blobs
- queue_size [default: 3] — Specify queue_size of input image subscribers
- threshold_step [default: 10.0] — Step of the thresholds from min_threshold to max_threshold
- min_threshold [default: 50.0] — The minimum threshold to binarize the image
- max_threshold [default: 220.0] — The maximum threshold (exclusive) to binarize the image
- min_repeatability [default: 2] — The minimum number of the binarized images in which a blob is detected
- min_dist_between_blobs [default: 10.0] — The blobs located closer than min_dist_between_blobs are merged
- filter_by_color [default: true] — Filter the blobs by the color of the center
- blob_color [default: 255] — 0 to extract dark blobs and 255 to extract light blobs
- filter_by_area [default: true] — Filter the blobs by the area
- min_area [default: 25.0] — The minimum area (inclusive) of the blobs [pixel]
- max_area [default: 100000.0] — The maximum area (exclusive) of the blobs [pixel]
- filter_by_circularity [default: false] — Filter the blobs by the circularity (4*pi*area/perimeter^2)
- min_circularity [default: 0.8] — The minimum circularity (inclusive) of the blobs
- max_circularity [default: 1.0] — The maximum circularity (exclusive) of the blobs, 1.0 means no limit
- filter_by_inertia [default: false] — Filter the blobs by the inertia ratio (the minimum / maximum second central moment, the square of minor axis / major axis for an ellipse, 0: line, 1: circle)
- min_inertia_ratio [default: 0.1] — The minimum inertia ratio (inclusive) of the blobs
- max_inertia_ratio [default: 1.0] — The maximum inertia ratio (exclusive) of the blobs, 1.0 means no limit
- filter_by_convexity [default: false] — Filter the blobs by the convexity (area / area of convex hull)
- min_convexity [default: 0.95] — The minimum convexity (inclusive) of the blobs
- max_convexity [default: 1.0] — The maximum convexity (exclusive) of the blobs, 1.0 means no limit
- launch/camshift.launch
-
- node_name [default: camshift]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]] — Histogram of tracked color object
- vmin [default: 10] — Min threshould of lightness.
- vmax [default: 230] — Max threshould of lightness.
- smin [default: 60] — Min value of saturation.
- x [default: 0] — Center x of the rectangle to track.
- y [default: 0] — Center y of the rectangle to track.
- width [default: 0] — Width of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- height [default: 0] — Height of the rectangle to track, 0 for none: at startup the histogram is used instead, setting it to 0 at runtime stops tracking.
- launch/compare_histogram.launch
-
- node_name [default: compare_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the histogram
- queue_size [default: 3] — Specify queue_size of input image subscribers
- histogram_size [default: 64] — Number of bins of the histogram of each channel
- histogram_comparison_type [default: 0] — Histogram comparison method. 0: Correlation, 1: Chi-Square, 2: Intersection, 3: Bhattacharyya
- reference_histogram [default: []] — Reference of the histogram comparison: channels x histogram_size numbers in the layout of ~histogram, i.e. [b0, b1, ..., g0, g1, ..., r0, r1, ...] for BGR images, [v0, v1, ...] for gray images. A YAML list of integers and/or decimals (newlines are fine). [] to disable the comparison.
- launch/contour_moments.launch
-
- node_name [default: contour_moments]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 100] — Canny Edge low Threshold
- launch/convex_hull.launch
-
- node_name [default: convex_hull]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/corner_harris.launch
-
- node_name [default: corner_harris]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 200] — Threshold value of a circle around corners's norm
- launch/discrete_fourier_transform.launch
-
- node_name [default: discrete_fourier_transform]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 1] — Specigy queue_size of input image subscribers
- launch/dnn_depth_estimation.launch
-
- node_name [default: dnn_depth_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx) of the same input and output as MiDaS, empty for MiDaS v2.1 small
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 256] — Width of the network input, 256 for MiDaS v2.1 small
- input_height [default: 256] — Height of the network input, 256 for MiDaS v2.1 small
- launch/dnn_face_detection.launch
-
- node_name [default: dnn_face_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_face_recognition.launch
-
- node_name [default: dnn_face_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet face detection model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the SFace face recognition model (onnx), empty for the default
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- match_threshold [default: 0.363] — Threshold of the cosine similarity to recognize the face as the trained one
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data] — Directory to save and load the trained faces
- launch/dnn_facial_expression_recognition.launch
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the YuNet model (onnx), empty for the default for this OpenCV version
- recognition_model [default: ] — Path or URL of the facial expression recognition model (onnx), empty for MobileFaceNet of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- score_threshold [default: 0.9] — Threshold of the score to detect the faces
- nms_threshold [default: 0.3] — Threshold of the overlap of the faces to suppress, by non maximum suppression
- top_k [default: 5000] — Number of the candidates to keep before non maximum suppression
- launch/dnn_hand_pose_estimation.launch
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- palm_detection_model [default: ] — Path or URL of the MediaPipe palm detection model (onnx), empty for palm_detection_mediapipe_2023feb.onnx of opencv_zoo
- hand_pose_estimation_model [default: ] — Path or URL of the MediaPipe hand pose estimation model (onnx), empty for handpose_estimation_mediapipe_2023feb.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the palms and to estimate the hands
- nms_threshold [default: 0.3] — Threshold of the overlap of the hands to suppress, by non maximum suppression
- tracking [default: true] — Track the hands by their poses in the previous image, as MediaPipe, and run the palm detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the palm detection to find the new hands while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked hands by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_image_classification.launch
-
- node_name [default: dnn_image_classification]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model (onnx), empty for PP-ResNet50 of opencv_zoo, e.g. MobileNet of opencv_zoo (OpenCV 4.9 or later)
- classes [default: ] — Path or URL of the class names of the model, one class per line, or empty for the 1000 classes of ImageNet
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 224] — Width of the network input
- input_height [default: 224] — Height of the network input
- top_k [default: 5] — Number of the classes to publish
- softmax [default: true] — Apply softmax to the output of the model to get the probabilities, true for the models whose output is the logits (e.g. PP-ResNet50 and MobileNet of opencv_zoo), false for the models whose output is the probabilities
- launch/dnn_object_detection.launch
-
- node_name [default: dnn_object_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model_type [default: yolox] — yolox for the YOLOX models (onnx), or detection_model for the models of cv::dnn::DetectionModel, e.g. YOLO (darknet), SSD (caffe, tensorflow), with config, input_width, input_height, scale and swap_rb
- model [default: ] — Path or URL of the model (e.g. .onnx, .weights), empty for YOLOX-S trained on COCO of opencv_zoo
- config [default: ] — Path or URL of the network configuration (e.g. .cfg) of the model, or empty
- classes [default: ] — Path or URL of the class names, one name per line, or empty for the classes of COCO for yolox
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 640] — Width of the network input, a multiple of 32 for yolox
- input_height [default: 640] — Height of the network input, a multiple of 32 for yolox
- scale [default: 0.00392156862745098] — Multiplier of the pixel values for the network input, for detection_model
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB, for detection_model
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the objects
- nms_threshold [default: 0.4] — Threshold of the overlap of the objects to suppress, by non maximum suppression
- launch/dnn_pose_estimation.launch
-
- node_name [default: dnn_pose_estimation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- person_detection_model [default: ] — Path or URL of the MediaPipe person detection model (onnx), empty for person_detection_mediapipe_2023mar.onnx of opencv_zoo
- pose_estimation_model [default: ] — Path or URL of the MediaPipe pose estimation model (onnx), empty for pose_estimation_mediapipe_2023mar.onnx of opencv_zoo
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- confidence_threshold [default: 0.5] — Threshold of the confidence to detect the persons and to estimate their poses
- nms_threshold [default: 0.3] — Threshold of the overlap of the persons to suppress, by non maximum suppression
- tracking [default: true] — Track the persons by their poses in the previous image, as MediaPipe, and run the person detection every detection_interval images, otherwise every image
- detection_interval [default: 10] — Interval of the person detection to find the new persons while tracking
- smoothing [default: true] — Smooth the landmarks of the tracked persons by One Euro filter
- smoothing_min_cutoff [default: 0.05] — Minimum cutoff frequency (Hz) of One Euro filter, smaller is smoother when still
- smoothing_beta [default: 80.0] — Speed coefficient of One Euro filter, larger follows the fast motion with less lag
- smoothing_derivative_cutoff [default: 1.0] — Cutoff frequency (Hz) of the velocity of One Euro filter
- launch/dnn_semantic_segmentation.launch
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- model [default: ] — Path or URL of the model whose output is the scores of the classes for each pixel, empty for PP-HumanSeg of opencv_zoo
- classes [default: ] — Path or URL of the class names of the model, one name per line, the first one is the background, or empty for background and person of PP-HumanSeg
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 192] — Width of the network input
- input_height [default: 192] — Height of the network input
- scale [default: 0.00784313725490196] — Multiplier of the pixel values for the network input
- mean [default: 127.5] — Mean subtracted from the pixel values before the scale
- swap_rb [default: true] — Swap the red and blue channels, true for the models trained in RGB
- launch/dnn_text_detection.launch
-
- node_name [default: dnn_text_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- detection_model [default: ] — Path or URL of the text detection model of DB (onnx), empty for DB (ResNet-18, IC15) of opencv_zoo
- recognition_model [default: ] — Path or URL of the text recognition model of CRNN (onnx), empty for CRNN (English) of opencv_zoo, or none to detect the text only
- vocabulary [default: ] — Path or URL of the vocabulary of the recognition model, one character per line, or empty for 0-9 and a-z of CRNN (English)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- input_width [default: 736] — Width of the input of the detection model, a multiple of 32
- input_height [default: 736] — Height of the input of the detection model, a multiple of 32
- binary_threshold [default: 0.3] — Threshold of the text probability of the pixels
- polygon_threshold [default: 0.5] — Threshold of the score of the text regions
- unclip_ratio [default: 2.0] — Ratio to expand the detected text regions
- max_candidates [default: 200] — Maximum number of the text regions
- launch/dnn_tracking.launch
-
- node_name [default: dnn_tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: -1] — Tracking algorithm -1: the newest one of this OpenCV (VitTrack, NanoTrack or DaSiamRPN), 0: DaSiamRPN, 1: NanoTrack (OpenCV 4.7 or later), 2: VitTrack (OpenCV 4.9 or later)
- backend [default: auto] — Backend of cv::dnn: auto, cpu, opencl, opencl_fp16, cuda or cuda_fp16. auto uses CUDA when OpenCV is built with CUDA and a CUDA device is found, and the CPU otherwise.
- dasiamrpn_model [default: ] — dasiamrpn_model.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_cls1 [default: ] — dasiamrpn_kernel_cls1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- dasiamrpn_kernel_r1 [default: ] — dasiamrpn_kernel_r1.onnx of DaSiamRPN, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default
- nanotrack_backbone [default: ] — Backbone model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- nanotrack_neckhead [default: ] — Neck and head model (onnx) of NanoTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (NanoTrack v2)
- vittrack_model [default: ] — Model (onnx) of VitTrack, a path or URL (downloaded to ~/.ros/opencv_apps/models/ at the first time), empty for the default (object_tracking_vittrack_2023sep.onnx of opencv_zoo)
- launch/edge_detection.launch
-
- node_name [default: edge_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- edge_type [default: 0] — Specify edge dtection methods. 0: Sobel Derivatives, 1: Lapalace Operator, 2, Canny Edge Detector.
- canny_threshold1 [default: 100] — Specify second canny threashold value.
- canny_threshold2 [default: 200] — Specity first canny threashold value.
- apertureSize [default: 3] — Aperture size for the Sobel() operator.
- apply_blur_pre [default: true] — Flag, applying Blur() to input image
- postBlurSize [default: 13] — Aperture size for the Blur() to input image()
- postBlurSigma [default: 3.2] — Sigma for the GaussianBlur() to input image.
- apply_blur_post [default: false] — Flag, applying GaussinaBlur() to output(edge) image
- L2gradient [default: false] — Flag, L2Gradient
- launch/equalize_histogram.launch
-
- node_name [default: equalize_histogram]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- histogram_equalization_type [default: 0] — Specify histogram equaliztion methods. 0: Default, 1: Clahe
- clahe_clip_limit [default: 255.0] — The maximum allowed field value Clip Limit
- clahe_tile_size_x [default: 300] — The maximum allowed field value Threshold X Limit
- clahe_tile_size_y [default: 300] — The maximum allowed field value Threshold Y Limit
- use_opencl [default: true] — Enable or disable OpenCL
- launch/face_detection.launch
-
- node_name [default: face_detection]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: $(arg use_opencv3)]
- use_opencv4 [default: false]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.1.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.2.0-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: $(find opencv3)/../OpenCV-3.3.1-dev/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- face_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_frontalface_alt.xml] — Face dtection cascade Filename
- eyes_cascade_name [default: /usr/share/opencv/haarcascades/haarcascade_eye_tree_eyeglasses.xml] — Eye dtection cascade Filename
- launch/face_recognition.launch
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- use_opencv3 [default: false]
- use_opencv3_1 [default: false]
- use_opencv3_2 [default: false]
- use_opencv3_3 [default: false]
- use_opencv4 [default: false]
- debug_view [default: true]
- queue_size [default: 100] — Specigy queue_size of input image subscribers
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch
-
- node_name [default: fback_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/find_contours.launch
-
- node_name [default: find_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_low_threshold [default: 10] — Lower threshold for the internal Canny edge detector.
- launch/general_contours.launch
-
- node_name [default: general_contours]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- threshold [default: 100] — Treshold for the detecting edges.
- launch/goodfeature_track.launch
-
- node_name [default: goodfeature_track]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- max_corners [default: 23] — Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned.
- launch/hls_color_filter.launch
-
- node_name [default: hls_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- l_limit_max [default: 255] — The maximum allowed field value Luminance
- l_limit_min [default: 50] — The minimum allowed field value Luminance
- launch/hough_circles.launch
-
- node_name [default: hough_circles]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- canny_threshold [default: 200] — Upper threshold for the internal Canny edge detector.
- accumulator_threshold [default: 50] — Threshold for center detection.
- gaussian_blur_size [default: 9] — The size of gaussian blur (should be odd number)
- gaussian_sigma_x [default: 2] — Sigma x of gaussian kernel
- gaussian_sigma_y [default: 2] — Sigma y of gaussian kernel
- dp [default: 2] — The inverse ratio of resolution.
- min_circle_radius [default: 0] — The minimum size of the circle, If unknown, put zero as default
- max_circle_radius [default: 0] — The maximum size of the circle, If unknown, put zero as default.
- launch/hough_lines.launch
-
- node_name [default: hough_lines]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hough_type [default: 0] — Apecify Hough transform type, 0 for Standard Hough Detection and 1 for Probabilistic Hough Detection
- threshold [default: 150] — Threshould value for hough line detection
- rho [default: 1.0] — The resolution of the parameter r in pixels.
- theta [default: 1.0] — The resolution of the parameter theta in degrees.
- minLineLength [default: 30] — The minimum number of points that can form a line.
- maxLineGrap [default: 10] — The maximum gap between two points to be considered in the same line.
- launch/hsv_color_filter.launch
-
- node_name [default: hsv_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- h_limit_max [default: 250] — The maximum allowed field value Hue
- h_limit_min [default: 0] — The minimum allowed field value Hue
- s_limit_max [default: 255] — The maximum allowed field value Saturation
- s_limit_min [default: 150] — The minimum allowed field value Saturation
- v_limit_max [default: 255] — The maximum allowed field value Value
- v_limit_min [default: 50] — The minimum allowed field value Value
- launch/lab_color_filter.launch
-
- node_name [default: lab_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- l_limit_max [default: 255] — The maximum allowed field value L*
- l_limit_min [default: 50] — The minimum allowed field value L*
- a_limit_max [default: 250] — The maximum allowed field value a*
- a_limit_min [default: 0] — The minimum allowed field value a*
- b_limit_max [default: 255] — The maximum allowed field value b*
- b_limit_min [default: 150] — The minimum allowed field value b*
- launch/line_segment_detector.launch
-
- node_name [default: line_segment_detector]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show line segment image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- lsd_refine_type [default: 0] — Line Segment Detector Modes. 0: No refinement applied, 1: Standard refinement is applied, 2, Advanced refinement is applied.
- lsd_scale [default: 0.8] — The scale of the image that will be used to find the lines. Range [0.1..1]
- lsd_sigma_scale [default: 0.6] — Sigma for Gaussian filter. It is computed as sigma = _sigma_scale/_scale
- lsd_quant [default: 2.0] — Bound to the quantization error on the gradient norm
- lsd_angle_threshold [default: 22.5] — Gradient angle tolerance in degrees
- lsd_log_eps [default: 0.0] — Detection threshold: -log10(NFA) > log_eps. Used only when advanced refinement is chosen
- lsd_density_threshold [default: 0.7] — Minimal density of aligned region points in the enclosing rectangle
- lsd_n_bins [default: 1024] — Number of bins in pseudo-ordering of gradient modulus
- lsd_line_length_threshold [default: 100.0] — Threshold of line length. Shorter lines are not published nor drawn.
- launch/lk_flow.launch
-
- node_name [default: lk_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- quality_level [default: 0.01] — Parameter characterizing the minimal acceptance quality of image corners.
- min_distance [default: 10] — Minimum possible Euclidean distance between the returned corners.
- block_size [default: 3] — Size of an average block for computing a derivative covariation matrix over each pixel neighborhood.
- harris_k [default: 0.04] — Free parameter of the Harris detector
- launch/match_template.launch
-
- node_name [default: match_template]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the match, the template can be selected with mouse on the window
- queue_size [default: 3] — Specify queue_size of input image subscribers
- match_method [default: 5] — Matching method. 0: TM_SQDIFF, 1: TM_SQDIFF_NORMED, 2: TM_CCORR, 3: TM_CCORR_NORMED, 4: TM_CCOEFF, 5: TM_CCOEFF_NORMED
- match_threshold [default: 0.0] — Minimum similarity of a match (score of TM_CCORR_NORMED and TM_CCOEFF_NORMED, 1 - score of TM_SQDIFF_NORMED), not used by the methods which are not normalized
- max_matches [default: 1] — Maximum number of the matches. 1: the best match only, more than 1: the matches above match_threshold, after a non-maximum suppression
- template_file [default: ] — File name of the template image, it is replaced by the image on ~template topic
- mask_file [default: ] — File name of the mask image of the template (non-zero pixels are used), it is replaced by the image on ~mask topic
- launch/morphology.launch
-
- node_name [default: morphology]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- morph_operator [default: 0] — Morphology Operation Methods 0: Opening, 1: Closing, 2: Gradient, 3: Top Hat, 4: Black Hat
- morph_element [default: 0] — Type of the kernel 0: Rect, 1: Cross, 2: Ellipse
- morph_size [default: 0] — Radius of the kernel, whose size is 2 * morph_size + 1.
- launch/people_detect.launch
-
- node_name [default: people_detect]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- hit_threshold [default: 0] — Threshold for the distance between features and SVM classifying plane
- win_stride [default: 8] — Window stride. It must be a multiple of block stride.
- padding [default: 32] — Padding of the detection window in pixels, of cv::HOGDescriptor::detectMultiScale().
- scale0 [default: 1.05] — Coefficient of the detection window increase.
- group_threshold [default: 2] — Coefficient to regulate the similarity threshold. When detected, some objects can be covered by many rectangles. 0 means not to perform grouping.
- launch/phase_corr.launch
-
- node_name [default: phase_corr]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/pyramids.launch
-
- node_name [default: pyramids]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show pyramids image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- pyramids_type [default: 0] — Specify pyramids Up/Down. 0: Up size(zoom in), 1: Down size(zoom out).
- num_of_pyramids [default: 0] — Number of Up/Down sampling.
- launch/qrcode_detection.launch
-
- node_name [default: qrcode_detection]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show the result
- queue_size [default: 3] — Specify queue_size of input image subscribers
- launch/rgb_color_filter.launch
-
- node_name [default: rgb_color_filter]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- r_limit_max [default: 250] — The maximum allowed field value Red
- r_limit_min [default: 50] — The minimum allowed field value Red
- g_limit_max [default: 200] — The maximum allowed field value Green
- g_limit_min [default: 100] — The minimum allowed field value Green
- b_limit_max [default: 150] — The maximum allowed field value Blue
- b_limit_min [default: 20] — The minimum allowed field value Blue
- launch/segment_objects.launch
-
- node_name [default: segment_objects]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/simple_flow.launch
-
- node_name [default: simple_flow]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- scale [default: 8] — Specify the scale factor to calculate optical flow.
- launch/smoothing.launch
-
- node_name [default: smoothing]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- filter_type [default: 0] — Smoothing Filter Methods. 0:Homogeneous blur, 1:Gaussian blur, 2:Median blur, 3:Bilateral Filter.
- kernel_size [default: 7] — Size of the kernel (only one because we use a square window). Must be odd.
- launch/threshold.launch
-
- node_name [default: threshold]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- apply_otsu [default: false] — Decide applying Otsu's algotirhm threshold. If this value is true, threshold value will be ignored
- threshold_type [default: 0] — Specify threshold types. 0: Binary threshold, 1: Binary inverted threshold, 2: Threshold truncated, 3: Threshold to zero, 4: Threshold to zero inverted
- threshold [default: 150] — threshold value
- max_binary [default: 255] — maximum value to use with the 0: Binary thresholding and 1: Binary inverted thresholding types.
- launch/tracking.launch
-
- node_name [default: tracking]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show tracking image
- queue_size [default: 3] — Specify queue_size of input image subscribers
- tracking_algorithm [default: 4] — Tracking algorithm 0: MIL, 1: BOOSTING, 2: MEDIANFLOW, 3: TLD, 4: KCF, 6: MOSSE, 7: CSRT
- launch/watershed_segmentation.launch
-
- node_name [default: watershed_segmentation]
- image [default: image] — The image topic. Should be remapped to the name of the real image topic.
- use_camera_info [default: false] — Indicates that the camera_info topic should be subscribed to to get the default input_frame_id. Otherwise the frame from the image message will be used.
- debug_view [default: true] — Specify whether the node displays a window to show edge image
- queue_size [default: 3] — Specigy queue_size of input image subscribers
- launch/adding_images.launch.xml
-
- node_name [default: adding_images]
- image1 [default: image1]
- image2 [default: image2]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- alpha [default: 0.5]
- gamma [default: 0.0]
- approximate_sync [default: false]
- launch/aruco_detection.launch.xml
-
- node_name [default: aruco_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- dictionary [default: DICT_4X4_50]
- marker_length [default: 0.0]
- rectified [default: false]
- launch/background_subtraction.launch.xml
-
- node_name [default: background_subtraction]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- method [default: 0]
- learning_rate [default: -1.0]
- launch/barcode_detection.launch.xml
-
- node_name [default: barcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/blob_detection.launch.xml
-
- node_name [default: blob_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold_step [default: 10.0]
- min_threshold [default: 50.0]
- max_threshold [default: 220.0]
- min_repeatability [default: 2]
- min_dist_between_blobs [default: 10.0]
- filter_by_color [default: true]
- blob_color [default: 255]
- filter_by_area [default: true]
- min_area [default: 25.0]
- max_area [default: 100000.0]
- filter_by_circularity [default: false]
- min_circularity [default: 0.8]
- max_circularity [default: 1.0]
- filter_by_inertia [default: false]
- min_inertia_ratio [default: 0.1]
- max_inertia_ratio [default: 1.0]
- filter_by_convexity [default: false]
- min_convexity [default: 0.95]
- max_convexity [default: 1.0]
- launch/camshift.launch.xml
-
- node_name [default: camshift]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram [default: [0.0, 255.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0, 0.0]]
- vmin [default: 10]
- vmax [default: 230]
- smin [default: 60]
- x [default: 0]
- y [default: 0]
- width [default: 0]
- height [default: 0]
- launch/compare_histogram.launch.xml
-
- node_name [default: compare_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_size [default: 64]
- histogram_comparison_type [default: 0]
- reference_histogram [default: ]
- launch/contour_moments.launch.xml
-
- node_name [default: contour_moments]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 100]
- launch/convex_hull.launch.xml
-
- node_name [default: convex_hull]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/corner_harris.launch.xml
-
- node_name [default: corner_harris]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 200]
- launch/discrete_fourier_transform.launch.xml
-
- node_name [default: discrete_fourier_transform]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 1]
- launch/dnn_depth_estimation.launch.xml
-
- node_name [default: dnn_depth_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- input_width [default: 256]
- input_height [default: 256]
- launch/dnn_face_detection.launch.xml
-
- node_name [default: dnn_face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_face_recognition.launch.xml
-
- node_name [default: dnn_face_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- match_threshold [default: 0.363]
- data_dir [default: ~/.ros/opencv_apps/dnn_face_data]
- launch/dnn_facial_expression_recognition.launch.xml
-
- node_name [default: dnn_facial_expression_recognition]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- backend [default: auto]
- score_threshold [default: 0.9]
- nms_threshold [default: 0.3]
- top_k [default: 5000]
- launch/dnn_hand_pose_estimation.launch.xml
-
- node_name [default: dnn_hand_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- palm_detection_model [default: ]
- hand_pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_image_classification.launch.xml
-
- node_name [default: dnn_image_classification]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 224]
- input_height [default: 224]
- top_k [default: 5]
- softmax [default: true]
- launch/dnn_object_detection.launch.xml
-
- node_name [default: dnn_object_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model_type [default: yolox]
- model [default: ]
- config [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 640]
- input_height [default: 640]
- scale [default: 0.00392156862745098]
- swap_rb [default: true]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.4]
- launch/dnn_pose_estimation.launch.xml
-
- node_name [default: dnn_pose_estimation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- person_detection_model [default: ]
- pose_estimation_model [default: ]
- backend [default: auto]
- confidence_threshold [default: 0.5]
- nms_threshold [default: 0.3]
- tracking [default: true]
- detection_interval [default: 10]
- smoothing [default: true]
- smoothing_min_cutoff [default: 0.05]
- smoothing_beta [default: 80.0]
- smoothing_derivative_cutoff [default: 1.0]
- launch/dnn_semantic_segmentation.launch.xml
-
- node_name [default: dnn_semantic_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- model [default: ]
- classes [default: ]
- backend [default: auto]
- input_width [default: 192]
- input_height [default: 192]
- scale [default: 0.00784313725490196]
- mean [default: 127.5]
- swap_rb [default: true]
- launch/dnn_text_detection.launch.xml
-
- node_name [default: dnn_text_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- detection_model [default: ]
- recognition_model [default: ]
- vocabulary [default: ]
- backend [default: auto]
- input_width [default: 736]
- input_height [default: 736]
- binary_threshold [default: 0.3]
- polygon_threshold [default: 0.5]
- unclip_ratio [default: 2.0]
- max_candidates [default: 200]
- launch/dnn_tracking.launch.xml
-
- node_name [default: dnn_tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: -1]
- backend [default: auto]
- dasiamrpn_model [default: ]
- dasiamrpn_kernel_cls1 [default: ]
- dasiamrpn_kernel_r1 [default: ]
- nanotrack_backbone [default: ]
- nanotrack_neckhead [default: ]
- vittrack_model [default: ]
- launch/edge_detection.launch.xml
-
- node_name [default: edge_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- edge_type [default: 0]
- canny_threshold1 [default: 100]
- canny_threshold2 [default: 200]
- apertureSize [default: 3]
- apply_blur_pre [default: true]
- postBlurSize [default: 13]
- postBlurSigma [default: 3.2]
- apply_blur_post [default: false]
- L2gradient [default: false]
- launch/equalize_histogram.launch.xml
-
- node_name [default: equalize_histogram]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- histogram_equalization_type [default: 0]
- clahe_clip_limit [default: 255.0]
- clahe_tile_size_x [default: 300]
- clahe_tile_size_y [default: 300]
- use_opencl [default: true]
- launch/face_detection.launch.xml
-
- node_name [default: face_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- face_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_frontalface_alt.xml]
- eyes_cascade_name [default: /usr/share/opencv4/haarcascades/haarcascade_eye_tree_eyeglasses.xml]
- launch/face_recognition.launch.xml
-
- launch_face_detection [default: true]
- launch_trainer [default: true]
- debug_view [default: true]
- queue_size [default: 100]
- image [default: image]
- data_dir [default: ~/.ros/opencv_apps/face_data]
- launch/fback_flow.launch.xml
-
- node_name [default: fback_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/find_contours.launch.xml
-
- node_name [default: find_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_low_threshold [default: 10]
- launch/general_contours.launch.xml
-
- node_name [default: general_contours]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- threshold [default: 100]
- launch/goodfeature_track.launch.xml
-
- node_name [default: goodfeature_track]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- max_corners [default: 23]
- launch/hls_color_filter.launch.xml
-
- node_name [default: hls_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- launch/hough_circles.launch.xml
-
- node_name [default: hough_circles]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- canny_threshold [default: 200.0]
- accumulator_threshold [default: 50.0]
- gaussian_blur_size [default: 9]
- gaussian_sigma_x [default: 2.0]
- gaussian_sigma_y [default: 2.0]
- dp [default: 2.0]
- min_circle_radius [default: 0]
- max_circle_radius [default: 0]
- launch/hough_lines.launch.xml
-
- node_name [default: hough_lines]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hough_type [default: 0]
- threshold [default: 150]
- rho [default: 1.0]
- theta [default: 1.0]
- minLineLength [default: 30.0]
- maxLineGrap [default: 10.0]
- launch/hsv_color_filter.launch.xml
-
- node_name [default: hsv_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- h_limit_max [default: 250]
- h_limit_min [default: 0]
- s_limit_max [default: 255]
- s_limit_min [default: 150]
- v_limit_max [default: 255]
- v_limit_min [default: 50]
- launch/lab_color_filter.launch.xml
-
- node_name [default: lab_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- l_limit_max [default: 255]
- l_limit_min [default: 50]
- a_limit_max [default: 250]
- a_limit_min [default: 0]
- b_limit_max [default: 255]
- b_limit_min [default: 150]
- launch/line_segment_detector.launch.xml
-
- node_name [default: line_segment_detector]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- lsd_refine_type [default: 0]
- lsd_scale [default: 0.8]
- lsd_sigma_scale [default: 0.6]
- lsd_quant [default: 2.0]
- lsd_angle_threshold [default: 22.5]
- lsd_log_eps [default: 0.0]
- lsd_density_threshold [default: 0.7]
- lsd_n_bins [default: 1024]
- lsd_line_length_threshold [default: 100.0]
- launch/lk_flow.launch.xml
-
- node_name [default: lk_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- quality_level [default: 0.01]
- min_distance [default: 10]
- block_size [default: 3]
- harris_k [default: 0.04]
- launch/match_template.launch.xml
-
- node_name [default: match_template]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- match_method [default: 5]
- match_threshold [default: 0.0]
- max_matches [default: 1]
- template_file [default: ]
- mask_file [default: ]
- launch/morphology.launch.xml
-
- node_name [default: morphology]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- morph_operator [default: 0]
- morph_element [default: 0]
- morph_size [default: 0]
- launch/people_detect.launch.xml
-
- node_name [default: people_detect]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- hit_threshold [default: 0.0]
- win_stride [default: 8]
- padding [default: 32]
- scale0 [default: 1.05]
- group_threshold [default: 2]
- launch/phase_corr.launch.xml
-
- node_name [default: phase_corr]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/pyramids.launch.xml
-
- node_name [default: pyramids]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- pyramids_type [default: 0]
- num_of_pyramids [default: 1]
- launch/qrcode_detection.launch.xml
-
- node_name [default: qrcode_detection]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/rgb_color_filter.launch.xml
-
- node_name [default: rgb_color_filter]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- r_limit_max [default: 250]
- r_limit_min [default: 50]
- g_limit_max [default: 200]
- g_limit_min [default: 100]
- b_limit_max [default: 150]
- b_limit_min [default: 20]
- launch/segment_objects.launch.xml
-
- node_name [default: segment_objects]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- launch/simple_flow.launch.xml
-
- node_name [default: simple_flow]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- scale [default: 8]
- launch/smoothing.launch.xml
-
- node_name [default: smoothing]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- filter_type [default: 0]
- kernel_size [default: 7]
- launch/threshold.launch.xml
-
- node_name [default: threshold]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- apply_otsu [default: false]
- threshold_type [default: 0]
- threshold [default: 150]
- max_binary [default: 255]
- launch/tracking.launch.xml
-
- node_name [default: tracking]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
- tracking_algorithm [default: 4]
- launch/watershed_segmentation.launch.xml
-
- node_name [default: watershed_segmentation]
- image [default: image]
- use_camera_info [default: false]
- debug_view [default: true]
- queue_size [default: 3]
Messages
- Circle [Source]
- CircleArray [Source]
- CircleArrayStamped [Source]
- Contour [Source]
- ContourArray [Source]
- ContourArrayStamped [Source]
- Detection [Source]
- DetectionArray [Source]
- DetectionArrayStamped [Source]
- Face [Source]
- FaceArray [Source]
- FaceArrayStamped [Source]
- Flow [Source]
- FlowArray [Source]
- FlowArrayStamped [Source]
- FlowStamped [Source]
- Keypoint [Source]
- Line [Source]
- LineArray [Source]
- LineArrayStamped [Source]
- Moment [Source]
- MomentArray [Source]
- MomentArrayStamped [Source]
- Point2D [Source]
- Point2DArray [Source]
- Point2DArrayStamped [Source]
- Point2DStamped [Source]
- Rect [Source]
- RectArray [Source]
- RectArrayStamped [Source]
- RotatedRect [Source]
- RotatedRectArray [Source]
- RotatedRectArrayStamped [Source]
- RotatedRectStamped [Source]
- Size [Source]
- Skeleton [Source]
- SkeletonArray [Source]
- SkeletonArrayStamped [Source]