 ROS Index
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README

| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) |  |
|
| ROS 2 Jazzy (u24.04) |  |
|
| ROS 2 Kilted (u24.04) |  |
|
| ROS 2 Lyrical (u26.04) |  |
|
| ROS 2 Rolling (u26.04) |  |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) |  |
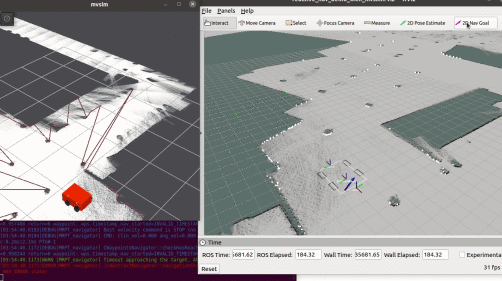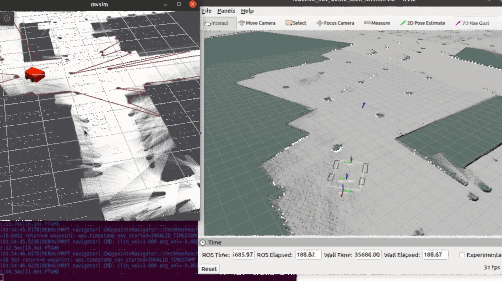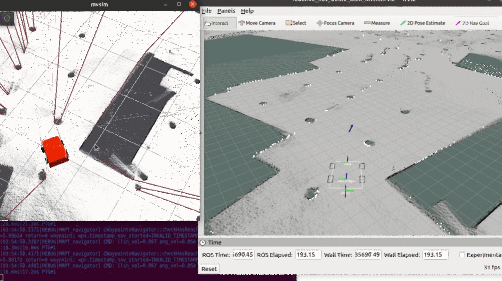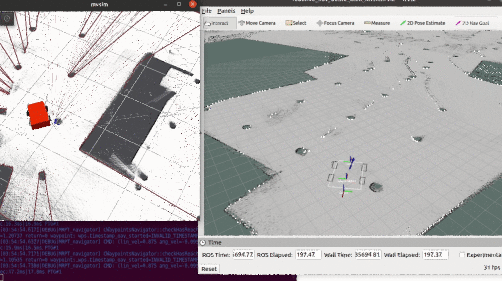
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros2 |
| Last Updated | 2026-11-19 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_map_server | 2.9.0 |
| mrpt_msgs_bridge | 2.9.0 |
| mrpt_nav_interfaces | 2.9.0 |
| mrpt_navigation | 2.9.0 |
| mrpt_pf_localization | 2.9.0 |
| mrpt_pointcloud_pipeline | 2.9.0 |
| mrpt_reactivenav2d | 2.9.0 |
| mrpt_tps_astar_planner | 2.9.0 |
| mrpt_trajectory_follower | 2.9.0 |
| mrpt_tutorials | 2.9.0 |
README
| Distro | Build dev | Release |
|---|---|---|
| ROS 2 Humble (u22.04) | |
|
| ROS 2 Jazzy (u24.04) | |
|
| ROS 2 Kilted (u24.04) | |
|
| ROS 2 Lyrical (u26.04) | |
|
| ROS 2 Rolling (u26.04) | |
| EOL Distro | Last version |
|---|---|
| ROS 2 Iron (u22.04) | |
mrpt_navigation
This repository provides packages that wrap functionality in the Mobile Robot Programming Toolkit (MRPT) related to localization and navigation. MRPT SLAM and sensor access are wrapped into other ROS repositories.
The latest SLAM framework, whose maps are compatible with this repository for localization, is MOLA.
How to cite
If you use mrpt_tps_astar_planner in your work, please cite the paper that describes it
(arXiv:2611.09210):
@misc{blanco2026tpsastar,
  title         = {{TPS-A*}: Path Planning for Any-Shape Vehicles with Certified Collision Checking in Trajectory Parameter Space},
  author        = {Blanco-Claraco, Jos{\'e} Luis and Rai, Shravan S. and Ca{\~n}adas-Ar{\'a}nega, Fernando and Torres-Moreno, Jos{\'e} Luis and Moreno-{\'U}beda, Jos{\'e} Carlos},
  year          = {2026},
  eprint        = {2611.09210},
  archivePrefix = {arXiv},
  primaryClass  = {cs.RO},
  url           = {https://arxiv.org/abs/2611.09210}
}
Related papers (newest first)
[IEEE RAM 2023](https://ieeexplore.ieee.org/abstract/document/10355540/) ```bibtex @ARTICLE{xiao2023barn, author = {Xiao, Xuesu and Xu, Zifan and Warnell, Garrett and Stone, Peter and Gebelli Guinjoan, Ferran and T Rodrigues, Romulo and Bruyninckx, Herman and Mandala, Hanjaya and Christmann, Guilherme and Blanco, Jos{\'{e}}-Luis and Somashekara Rai, Shravan}, month = {{aug}}, title = {Autonomous Ground Navigation in Highly Constrained Spaces: Lessons learned from The 2nd BARN Challenge at ICRA 2023}, journal = {IEEE Robotics & Automation Magazine}, volume = {30}, number = {4}, year = {2023}, url = {https://ieeexplore.ieee.org/abstract/document/10355540/}, doi = {10.1109/MRA.2023.3322920}, pages = {91--97} } ``` IJARS 2015 ([DOI](https://doi.org/10.5772/60563)) ```bibtex @ARTICLE{jaimez2015efficient, author = {Jaimez-Tarifa, Mariano and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Blanco, Jos{\'{e}}-Luis}, title = {Efficient Reactive Navigation with Exact Collision Determination for 3D Robot Shapes}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {63}, year = {2015}, doi = {10.5772/60563} } ``` IJARS 2015 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2015tps_rrt.pdf)) ```bibtex @ARTICLE{bellone2015tprrt, author = {Blanco, Jos{\'{e}}-Luis and Bellone, Mauro and Gim{\'{e}}nez-Fern{\'{a}}ndez, Antonio}, month = {{{may}}}, title = {TP-Space RRT: Kinematic path planning of non-holonomic any-shape vehicles}, journal = {International Journal of Advanced Robotic Systems}, volume = {12}, number = {55}, year = {2015}, url = {http://www.intechopen.com/journals/international_journal_of_advanced_robotic_systems/tp-space-rrt-ndash-kinematic-path-planning-of-non-holonomic-any-shape-vehicles}, doi = {10.5772/60463} } ``` IJRR 2010 ([PDF](https://ingmec.ual.es/~jlblanco/papers/blanco2010ofn_IJRR.pdf)), particle filter used in `mrpt_pf_localization` ```bibtex @ARTICLE{blanco2010ofn, author = {Blanco, Jos{\'{e}}-Luis and Gonz{\'{a}}lez-Jim{\'{e}}nez, Javier and Fern{\'{a}}ndez-Madrigal, Juan-Antonio}, title = {Optimal Filtering for Non-Parametric Observation Models: Applications to Localization and SLAM}, journal = {The International Journal of Robotics Research}, volume = {29}, File truncated at 100 lines [see the full file](https://github.com/mrpt-ros-pkg/mrpt_navigation/tree/ros2/README.md)CONTRIBUTING
|
mrpt_navigation repositorymrpt_local_obstacles mrpt_localization mrpt_map mrpt_msgs_bridge mrpt_navigation mrpt_rawlog mrpt_reactivenav2d mrpt_tutorials |
ROS Distro
|
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros1 |
| Last Updated | 2026-11-17 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_local_obstacles | 1.0.7 |
| mrpt_localization | 1.0.7 |
| mrpt_map | 1.0.7 |
| mrpt_msgs_bridge | 1.0.7 |
| mrpt_navigation | 1.0.7 |
| mrpt_rawlog | 1.0.7 |
| mrpt_reactivenav2d | 1.0.7 |
| mrpt_tutorials | 1.0.7 |
README
| Distro | Build dev | Build release | Stable sync |
|---|---|---|---|
| ROS1 Noetic (u20.04) |  |
mrpt_navigation
This repository provides packages and tools related to the Mobile Robot Programming Toolkit (MRPT).
- ROS wiki: http://wiki.ros.org/mrpt_navigation
- Compiling instructions: http://wiki.ros.org/mrpt_navigation/Tutorials/Installing
- Usage examples and tutorials: http://wiki.ros.org/mrpt_navigation/Tutorials
- Branches:
-
ros1: Intended for use with latest MRPT versions (>=2.0.x) and ROS1. -
compat-mrpt-1.3: DEPRECATED. Stall branch, archived for backwards compatibility with MRPT versions 1.3.x or older.
-
Demo videos
- Localization with particle filters:

CONTRIBUTING
|
|
mrpt_navigation repositorymrpt_local_obstacles mrpt_localization mrpt_map mrpt_msgs_bridge mrpt_navigation mrpt_rawlog mrpt_reactivenav2d mrpt_tutorials |
ROS Distro
|
Repository Summary
| Checkout URI | https://github.com/mrpt-ros-pkg/mrpt_navigation.git |
| VCS Type | git |
| VCS Version | ros1 |
| Last Updated | 2026-11-17 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| mrpt_local_obstacles | 1.0.7 |
| mrpt_localization | 1.0.7 |
| mrpt_map | 1.0.7 |
| mrpt_msgs_bridge | 1.0.7 |
| mrpt_navigation | 1.0.7 |
| mrpt_rawlog | 1.0.7 |
| mrpt_reactivenav2d | 1.0.7 |
| mrpt_tutorials | 1.0.7 |
README
| Distro | Build dev | Build release | Stable sync |
|---|---|---|---|
| ROS1 Noetic (u20.04) | |
mrpt_navigation
This repository provides packages and tools related to the Mobile Robot Programming Toolkit (MRPT).
- ROS wiki: http://wiki.ros.org/mrpt_navigation
- Compiling instructions: http://wiki.ros.org/mrpt_navigation/Tutorials/Installing
- Usage examples and tutorials: http://wiki.ros.org/mrpt_navigation/Tutorials
- Branches:
-
ros1: Intended for use with latest MRPT versions (>=2.0.x) and ROS1. -
compat-mrpt-1.3: DEPRECATED. Stall branch, archived for backwards compatibility with MRPT versions 1.3.x or older.
-
Demo videos
- Localization with particle filters: