 ROS Index
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
 # RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
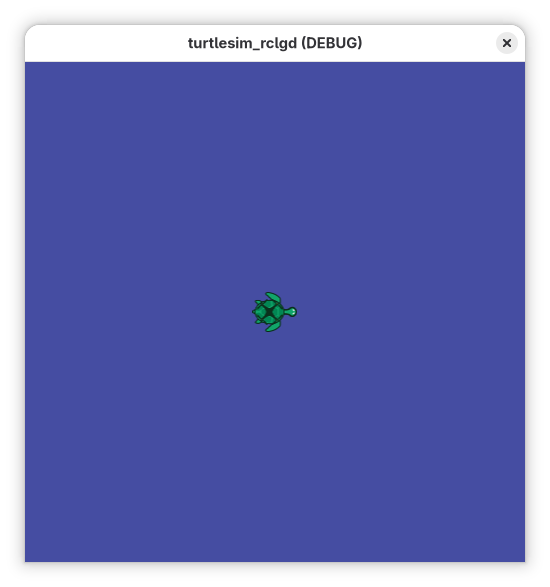
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.
CONTRIBUTING
Repository Summary
| Checkout URI | https://github.com/Ozuba/rclgd.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-11-04 |
| Dev Status | UNMAINTAINED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| colcon_rclgd | 3.0.0 |
| rclgd | 3.0.0 |
| rclgd_cli | 3.0.0 |
README
# RCLGD
**A native ROS 2 client library for the Godot Engine**
[](https://github.com/Ozuba/rclgd/actions/workflows/jazzy.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/kilted.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/lyrical.yaml)
[](https://github.com/Ozuba/rclgd/actions/workflows/rolling.yaml)
[](https://rclgd.readthedocs.io/) [](LICENSE) [](https://doi.org/10.5281/zenodo.18440938)
rclgd runs rclcpp inside Godot as a GDExtension, built on
ROS Babel Fish: no
rosbridge, no WebSockets, any message type at runtime. Nodes, topics,
services, actions, parameters, TF2, QoS, sim time and logging, all from
GDScript, with native typed classes (autocompletion, type checking) for the
interfaces your package.xml depends on.
Quick start
sudo apt install ros-jazzy-rclgd       # or build from source, below
ros2 rclgd create my_sim
colcon build --packages-select my_sim && source install/setup.bash
ros2 rclgd editor my_sim               # edit in Godot
ros2 run my_sim my_sim                 # run it like any ROS node
extends Node

var node: RosNode
var pub: RosPublisher
var timer: RosTimer  # keep a reference: dropping it cancels the timer

func _ready() -> void:
	node = RosNode.new()
	node.init("godot_talker")
	pub = node.create_publisher("/chatter", "std_msgs/msg/String")
	timer = node.create_timer(1.0, func():
		var msg := RosMsg.from_type("std_msgs/msg/String")
		msg.data = "Hello from Godot!"
		pub.publish(msg))
	node.get_logger().info("Talker started")
Topic, timer and action callbacks run on Godot’s main thread. Service callbacks and action goal callbacks run on a ROS thread: keep them off the scene tree.
Supported distros
| ROS 2 | Branch | Ubuntu | Install |
|---|---|---|---|
| Jazzy | jazzy |
24.04 | apt or source |
| Kilted | kilted |
24.04 | source |
| Lyrical | lyrical |
26.04 | source |
| Rolling | rolling |
26.04 | source |
All use Godot 4.7, downloaded and installed by the build. From source:
git clone -b <distro> --recurse-submodules https://github.com/Ozuba/rclgd.git src/rclgd
rosdep install --from-paths src --ignore-src -y
colcon build --packages-up-to rclgd
Documentation
Tutorials, the class reference and the CLI guide are at rclgd.readthedocs.io.
Contributing
Issues and pull requests are welcome. Open pull requests against rolling;
changes are merged into the other distro branches. Run the tests with
colcon test --packages-select rclgd.
rclgd is MIT licensed. If you use it in research, please cite it via CITATION.cff.